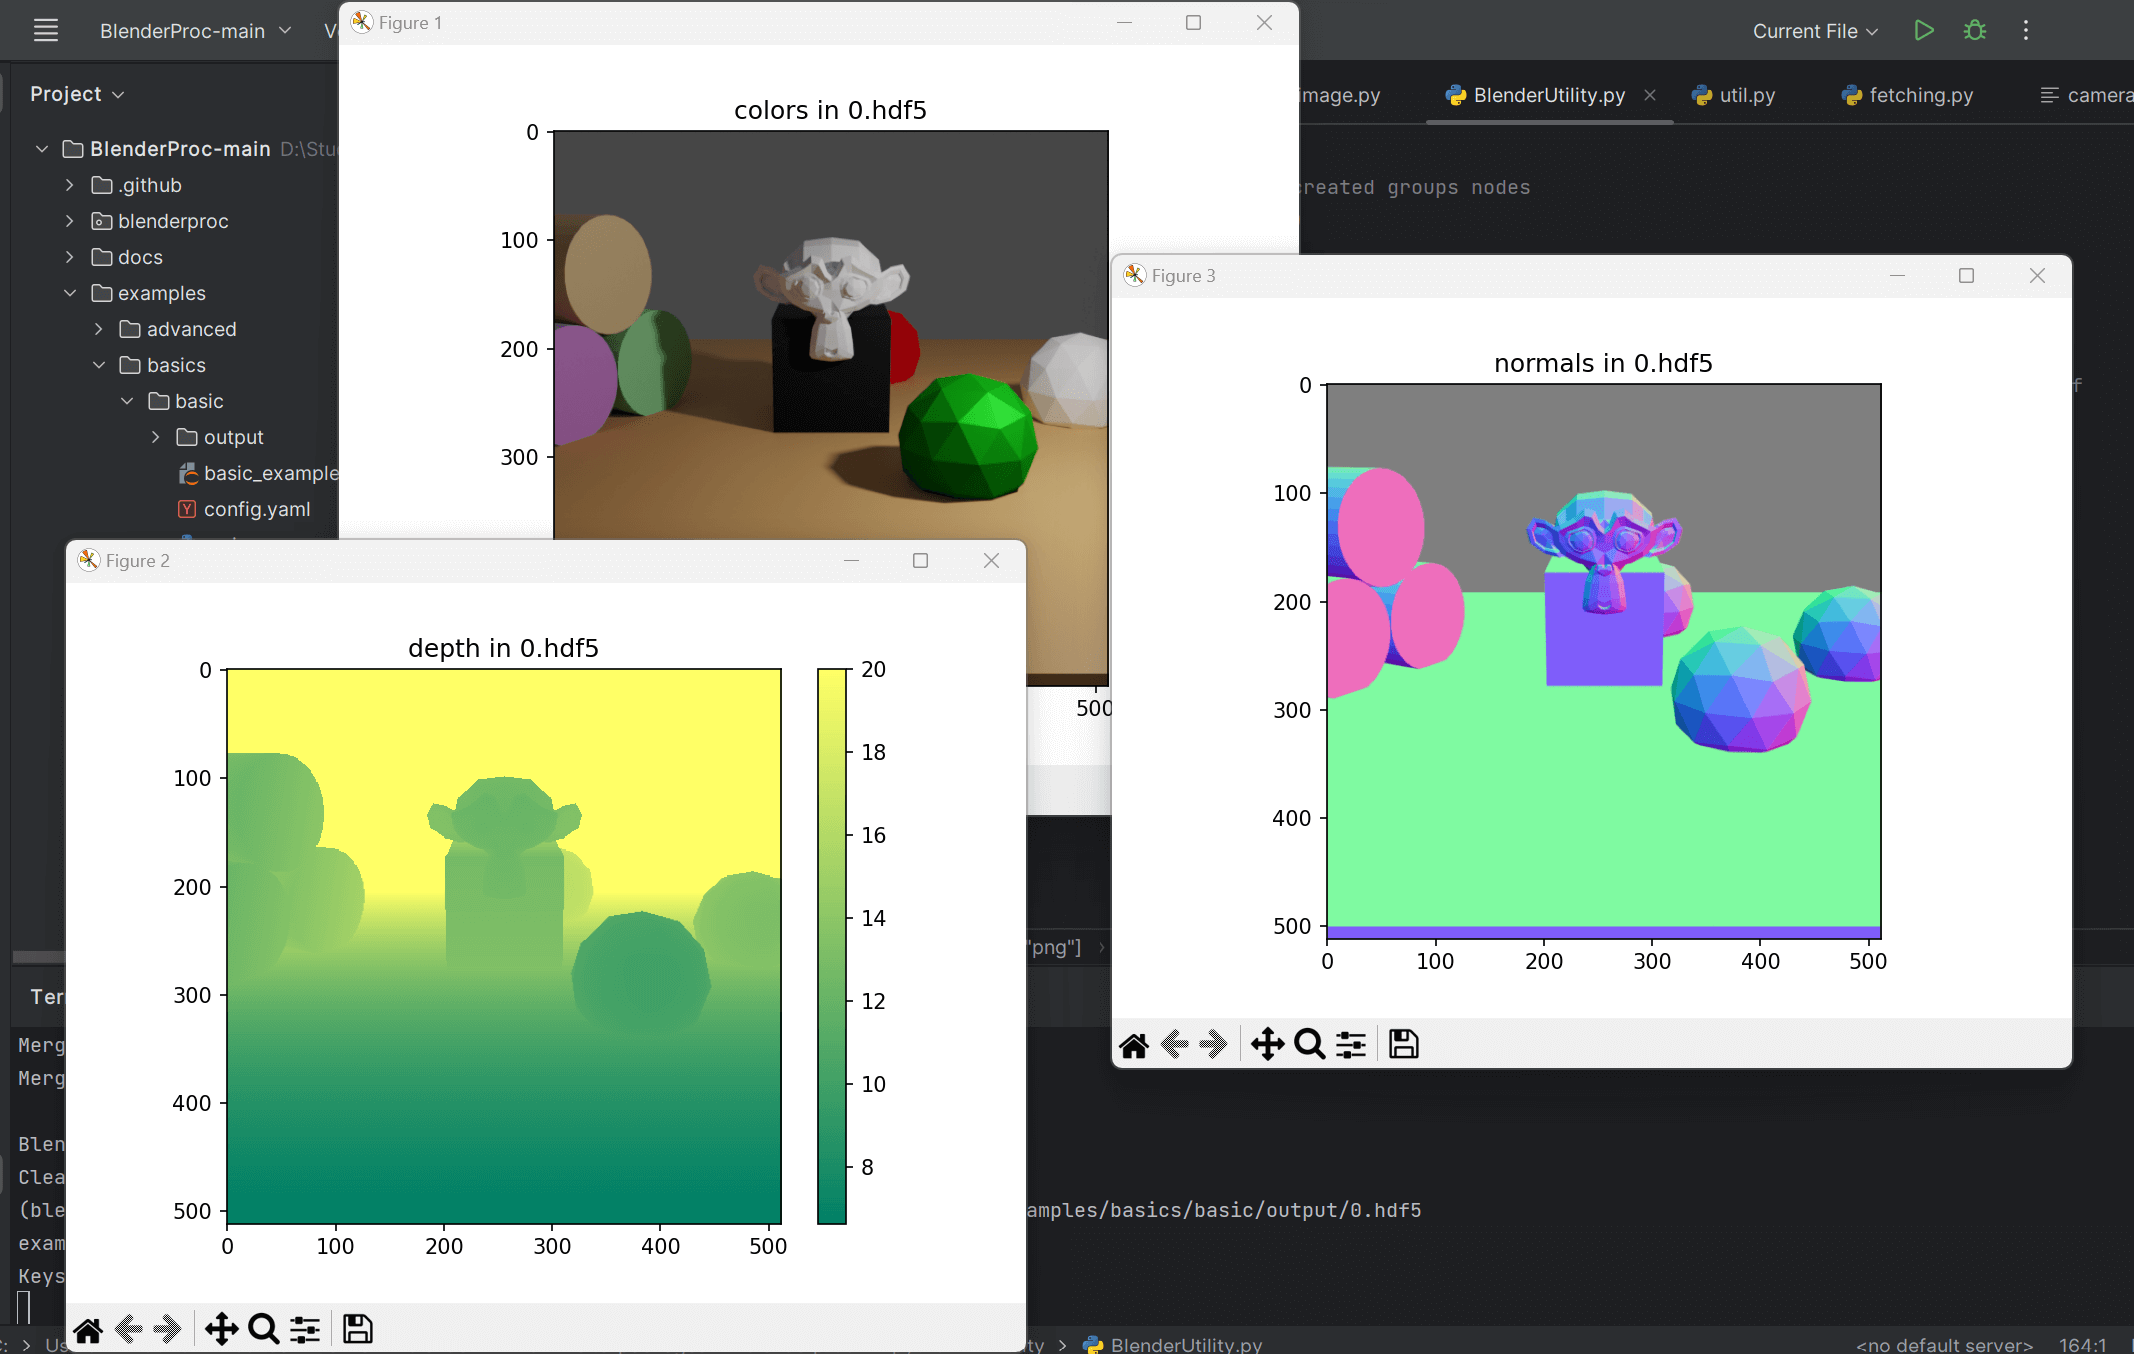
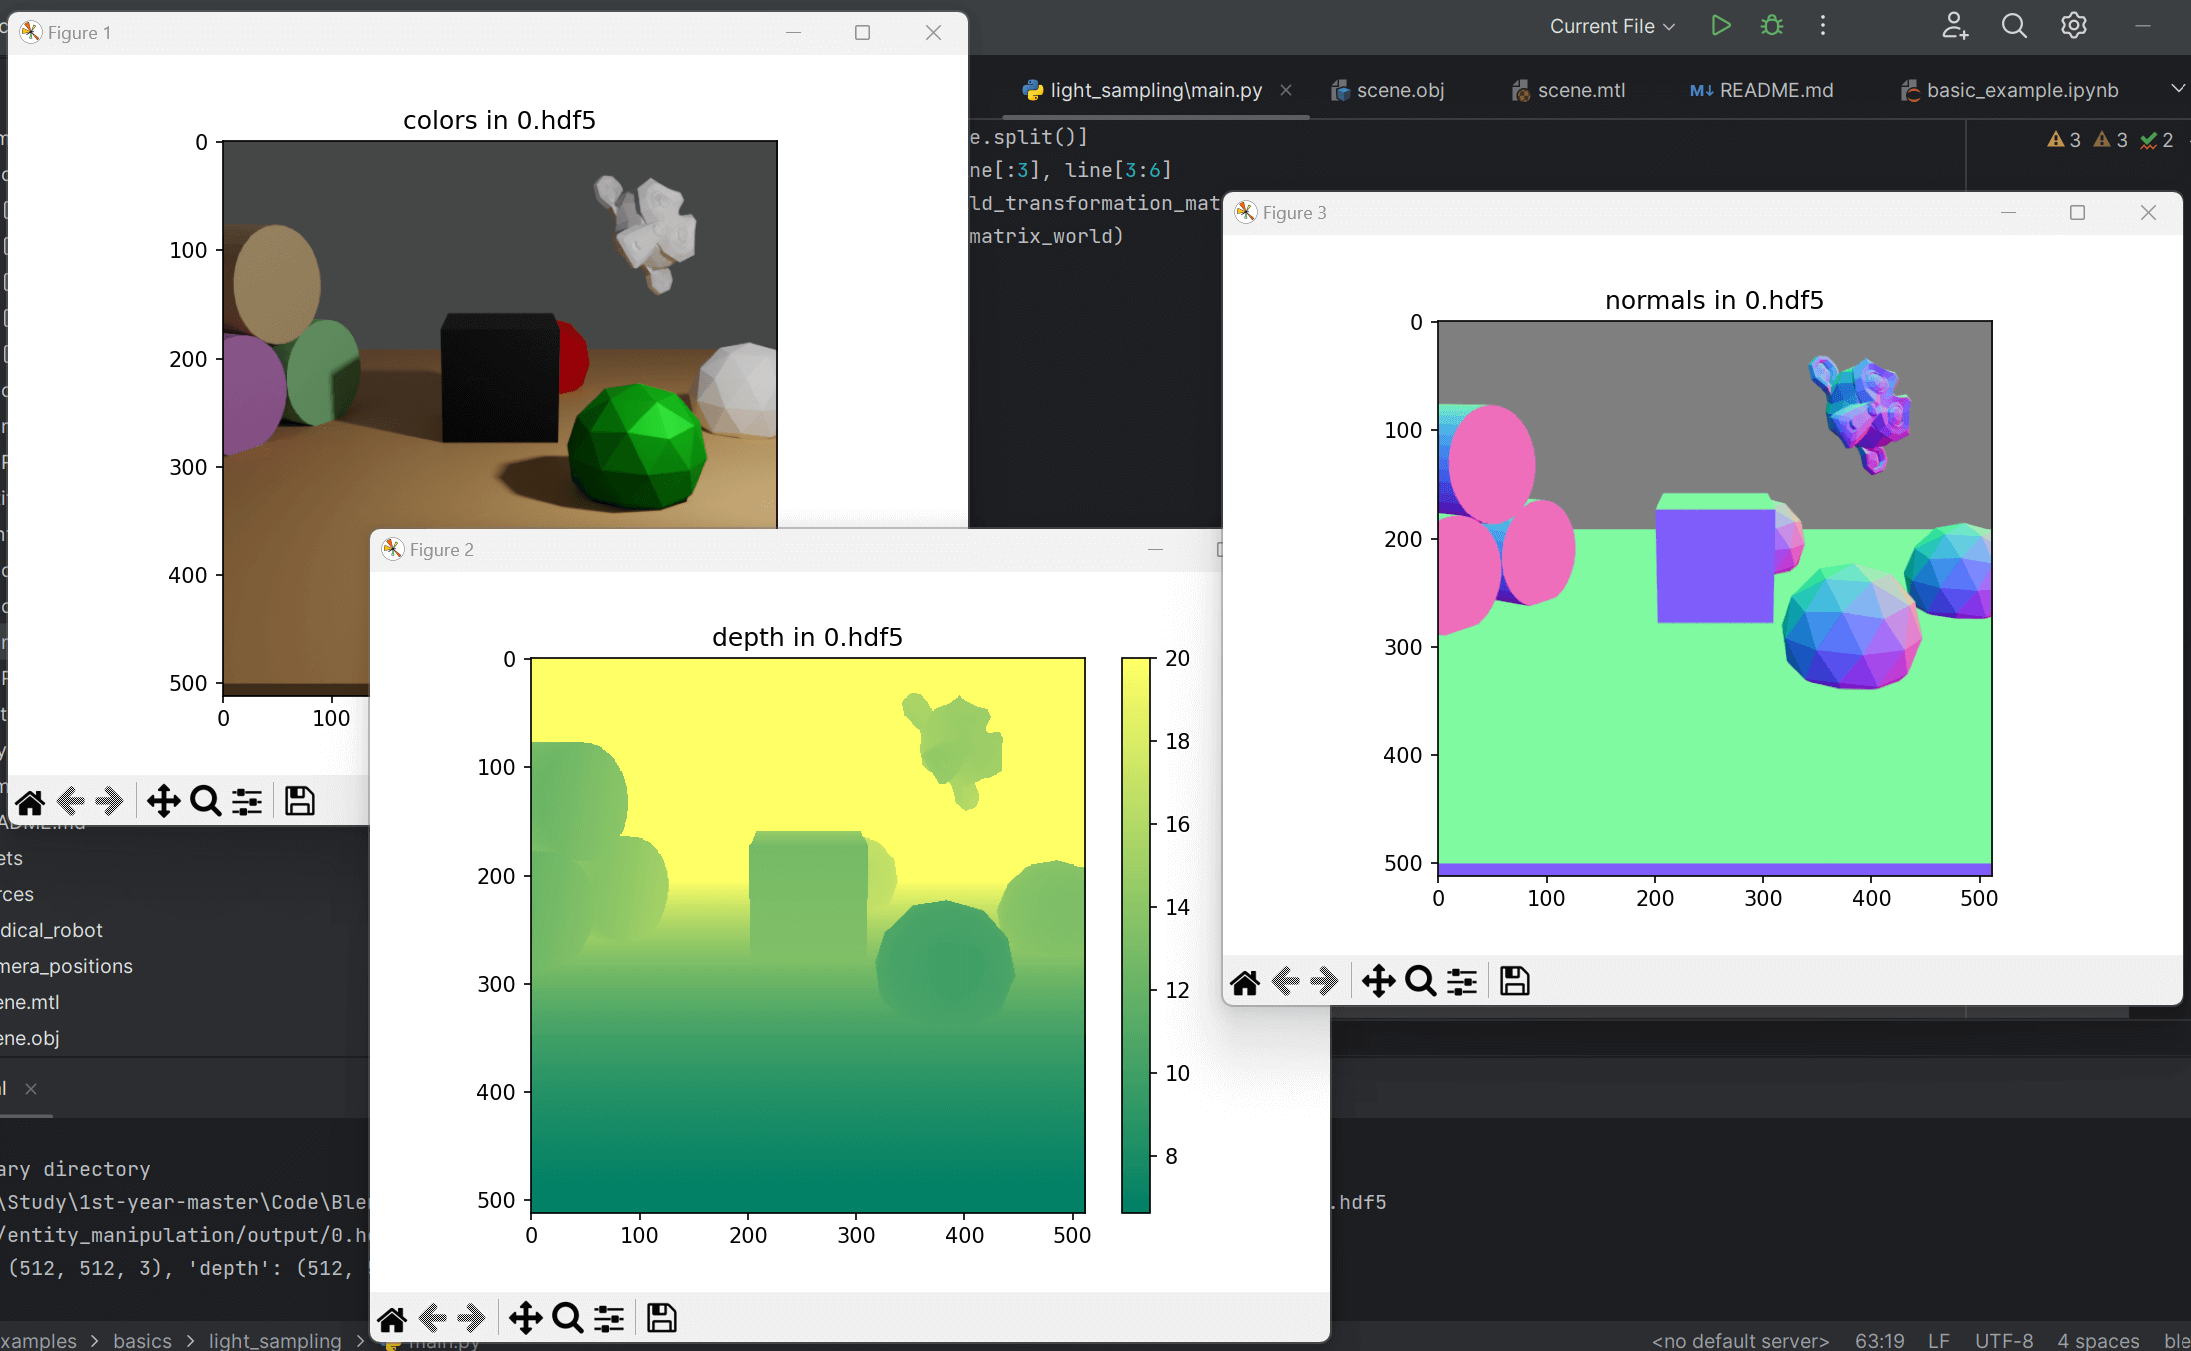
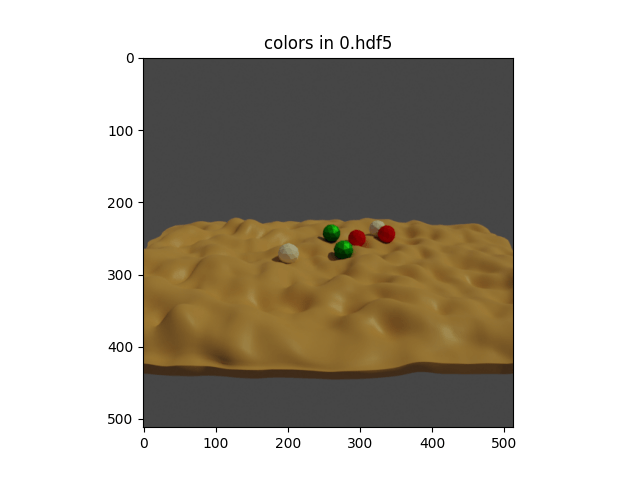
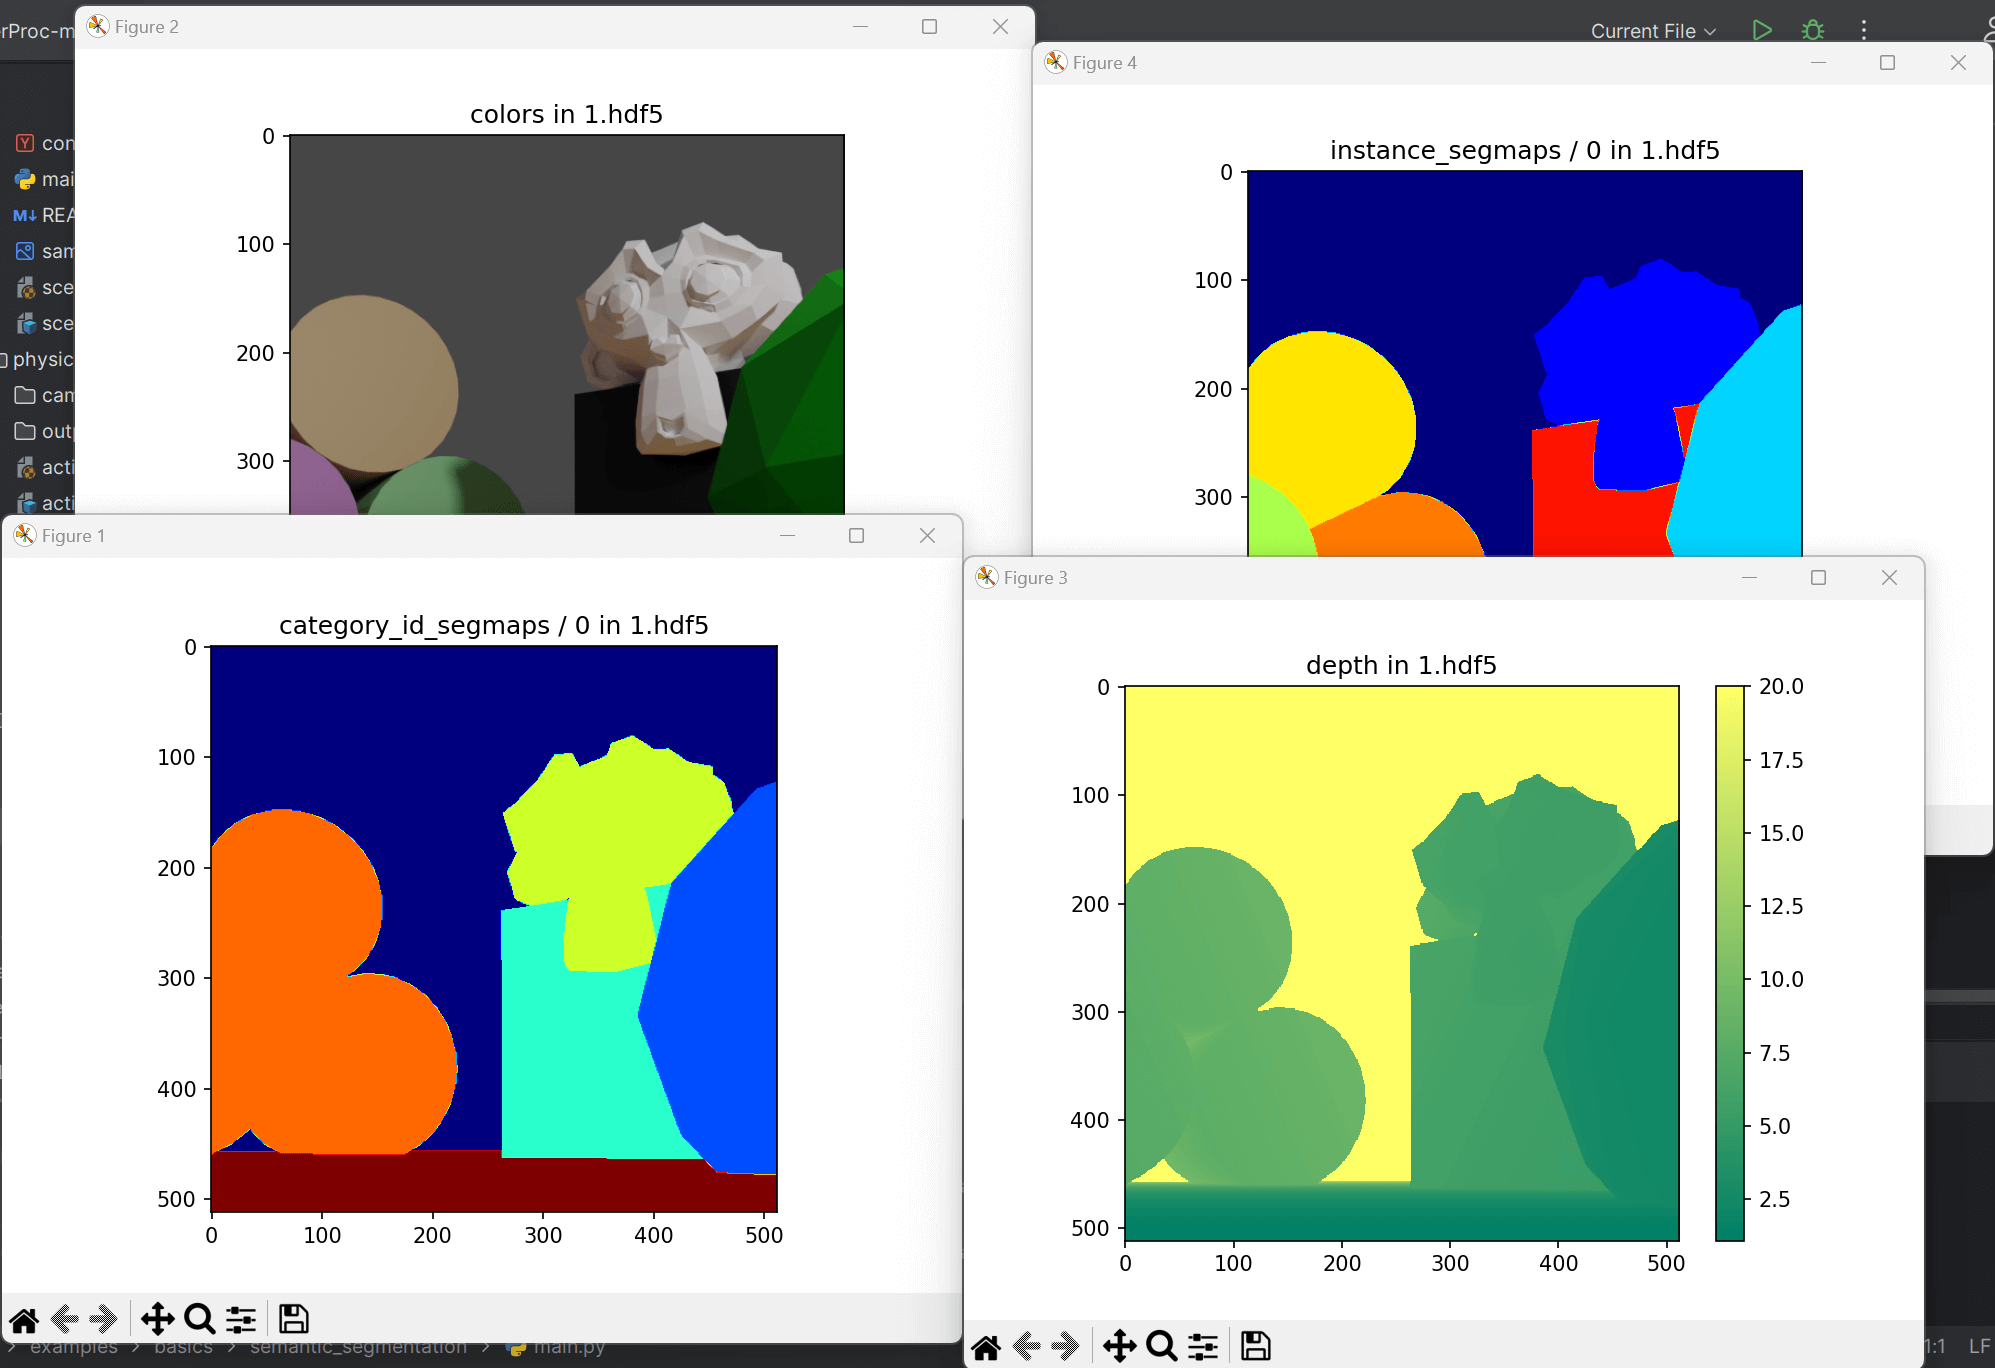
blenderproc run examples/basics/basic/main.py examples/resources/camera_positions examples/resources/scene.obj examples/basics/basic/output
即可开跑!我说婷婷,会报错:
shell
It seems the freeimage library which is necessary to read .exr files cannot be found on your computer.Gonna try to download it automatically.Imageio: 'freeimage-3.15.1-win64.dll' was not found on your computer; downloading it now.Error while fetching file: <urlopen error timed out>.Error while fetching file: The read operation timed out.Error while fetching file: <urlopen error timed out>.Error while fetching file: <urlopen error timed out>.
import blenderproc as bprocimport argparseparser = argparse.ArgumentParser()parser.add_argument('camera', help="Path to the camera file, should be examples/resources/camera_positions")parser.add_argument('scene', help="Path to the scene.obj file, should be examples/resources/scene.obj")parser.add_argument('output_dir', help="Path to where the final files, will be saved, could be examples/basics/basic/output")args = parser.parse_args()
初始化 blenderproc:
python
bproc.init()
从 args.scene 中载入模型场景:
python
objs = bproc.loader.load_obj(args.scene)
载入灯光:
python
# define a light and set its location and energy levellight = bproc.types.Light()light.set_type("POINT")light.set_location([5, -5, 5])light.set_energy(1000)
载入相机:这段代码的作用是设置相机分辨率,并读取相机位置信息并转换为齐次相机-世界变换矩阵。
python
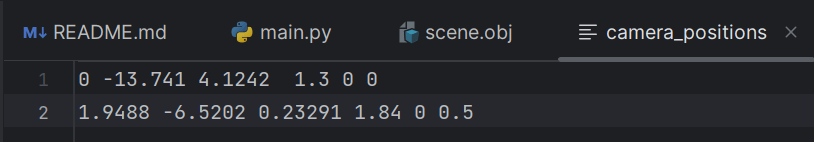
# define the camera resolution# 首先,调用 bproc.camera.set_resolution() 函数来定义相机的分辨率,该函数接受两个参数,即相机图像的宽度和高度。在这个示例中,我们将相机分辨率设置为 512x512。bproc.camera.set_resolution(512, 512)# read the camera positions file and convert into homogeneous camera-world transformationwith open(args.camera, "r") as f: for line in f.readlines(): # 使用一个 for 循环来逐行读取相机位置文件中的信息,并将每个位置信息转换为齐次变换矩阵,并通过调用 bproc.camera.add_camera_pose() 函数将其添加到 BlenderProc 中。 line = [float(x) for x in line.split()] position, euler_rotation = line[:3], line[3:6] matrix_world = bproc.math.build_transformation_mat(position, euler_rotation) bproc.camera.add_camera_pose(matrix_world)
渲染图像:
python
# activate normal and depth renderingbproc.renderer.enable_normals_output()bproc.renderer.enable_depth_output(activate_antialiasing=False)# bproc.renderer.set_noise_threshold(0.01) # this is the default value# render the whole pipelinedata = bproc.renderer.render()
# Find point of interest, all cam poses should look towards it# 通过调用 bproc.object.compute_poi(objs) 函数,计算出一组物体的几何中心点 poi,作为相机观察的焦点。poi = bproc.object.compute_poi(objs)# Sample five camera poses# 采样了五个随机的相机位置,渲染出 5 张图for i in range(5): # Sample random camera location above objects # 通过调用 np.random.uniform([-10, -10, 8], [10, 10, 12]) 函数,从一个三维坐标区间中随机取得一个相机位置,其中相机位置的 x、y 坐标范围为 [-10, 10],z 坐标范围为 [8, 12]。 location = np.random.uniform([-10, -10, 8], [10, 10, 12]) # Compute rotation based on vector going from location towards poi # 对于每一个相机位置,进一步计算其旋转矩阵 rotation_matrix,以便将相机的视线朝向 poi 的方向。 # 具体而言,调用 bproc.camera.rotation_from_forward_vec(poi - location, inplane_rot=np.random.uniform(-0.7854, 0.7854)) 函数,以相机位置和 poi 之间的向量作为前向向量,并通过 inplane_rot 参数加入少量的水平旋转随机性(其值在 [-0.7854, 0.7854] 范围内)来计算出旋转矩阵 rotation_matrix。 rotation_matrix = bproc.camera.rotation_from_forward_vec(poi - location, inplane_rot=np.random.uniform(-0.7854, 0.7854)) # Add homog cam pose based on location an rotation # 将相机位置和旋转信息组合为齐次相机-世界变换矩阵 cam2world_matrix = bproc.math.build_transformation_mat(location, rotation_matrix) # 将其添加到 BlenderProc 中,以便后续渲染时使用。这样,就实现了对场景从不同视角的渲染。 bproc.camera.add_camera_pose(cam2world_matrix)
Light sampling
Usage
shell
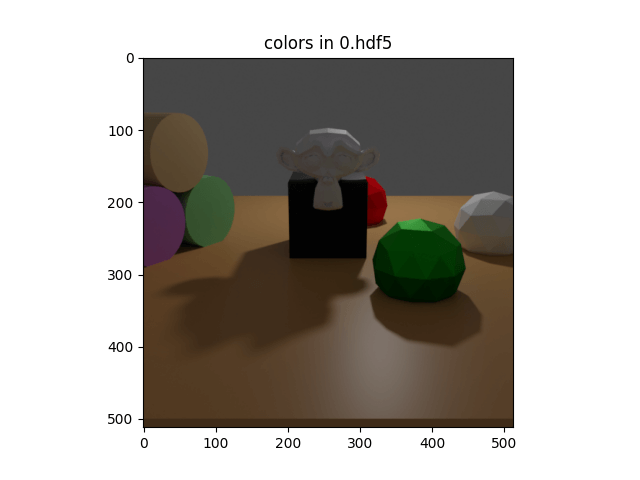
blenderproc run examples/basics/light_sampling/main.py examples/resources/camera_positions examples/resources/scene.obj examples/basics/light_sampling/output
Visualization
shell
blenderproc vis hdf5 examples/basics/light_sampling/output/0.hdf5
png
Code
python
# Define a lightlight = bproc.types.Light()light.set_type("POINT")# Sample its location in a shell around the point [1, 2, 3]light.set_location(bproc.sampler.shell( center=[1, 2, 3], radius_min=4, radius_max=7, elevation_min=15, elevation_max=70))light.set_energy(500)
最后,通过调用 light.set_energy(500) 函数,将光源的强度 energy 设置为 500 瓦特,以控制光照亮度。
python
# render the whole pipelinedata = bproc.renderer.render()# Collect states of all objectsobject_states = []for obj in objs: object_states.append({ "name": obj.get_name(), "local2world": obj.get_local2world_mat() })# Add states (they are the same for all frames here)data["object_states"] = [object_states] * bproc.utility.num_frames()# Collect state of the one lightlight_state = { "name": light.get_name(), "local2world": light.get_local2world_mat(), "energy": light.get_energy()}# Add states (its the same for all frames here)data["light_states"] = [light_state] * bproc.utility.num_frames()# Collect state of the camera at all framescam_states = []for frame in range(bproc.utility.num_frames()): cam_states.append({ "cam2world": bproc.camera.get_camera_pose(frame), "cam_K": bproc.camera.get_intrinsics_as_K_matrix() })# Adds states to the data dictdata["cam_states"] = cam_states
这段代码的含义是:
首先,通过调用 bproc.renderer.render() 函数,对当前的场景进行渲染,并将渲染结果存储在 data 变量中。
最后,通过循环遍历所有帧的索引 frame,将每一帧相机的相机坐标系到世界坐标系的变换矩阵 cam2world 和相机的内参矩阵 K 添加到 cam_states 列表中,并将其作为数据字典 data 中键名为 "cam_states" 的值,表示所有帧的相机状态。
Object selection and manipulation
Usage
shell
blenderproc run examples/basics/entity_manipulation/main.py examples/resources/scene.obj examples/basics/entity_manipulation/output
Visualization
shell
blenderproc vis hdf5 examples/basics/entity_manipulation/output/0.hdf5
png
Code
python
# load the objects into the sceneobjs = bproc.loader.load_obj(args.scene)# Find object with name Suzannesuzanne = bproc.filter.one_by_attr(objs, "name", "Suzanne")# Set its location and rotationsuzanne.set_location(np.random.uniform([0, 1, 2], [1, 2, 3]))suzanne.set_rotation_euler([1, 1, 0])
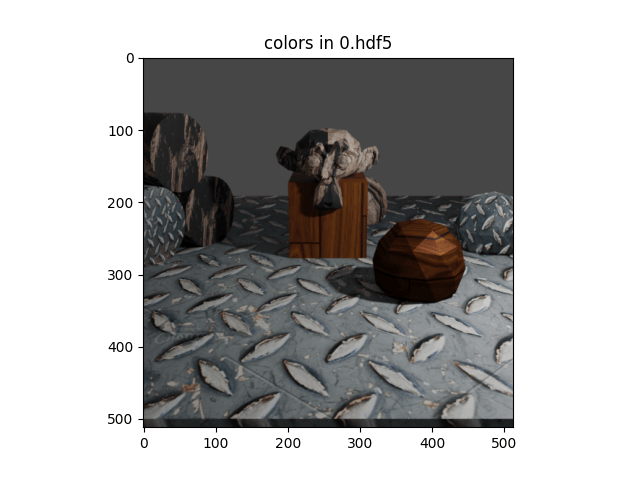
blenderproc run examples/basics/material_manipulation/main.py examples/basics/material_manipulation/scene.obj images examples/basics/material_manipulation/output
examples/basics/material_manipulation/main.py: path to the python file.
examples/basics/material_manipulation/scene.obj: path to the object file with the basic scene.
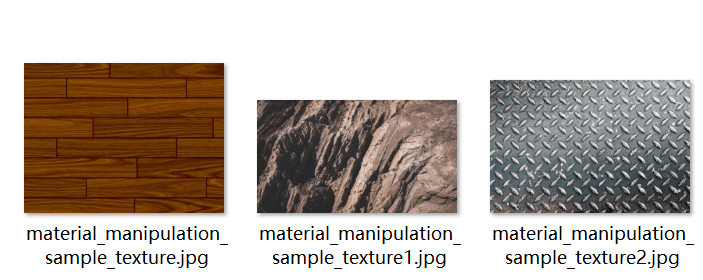
images: path to a folder with .jpg textures to be used in the sampling process.
examples/basics/material_manipulation/output: path to the output directory.
Visualization
shell
blenderproc vis hdf5 examples/basics/material_manipulation/output/0.hdf5
png
python
# Find all materialsmaterials = bproc.material.collect_all()# Find the material of the ground objectground_material = bproc.filter.one_by_attr(materials, "name", "Material.001")# Set its displacement based on its base color textureground_material.set_displacement_from_principled_shader_value("Base Color", multiply_factor=1.5)
# Collect all jpg images in the specified directoryimages = list(Path(args.image_dir).absolute().rglob("material_manipulation_sample_texture*.jpg"))for mat in materials: # Load one random image image = bpy.data.images.load(filepath=str(random.choice(images))) # Set it as base color of the current material mat.set_principled_shader_value("Base Color", image)
blenderproc run examples/basics/physics_positioning/main.py examples/basics/physics_positioning/active.obj examples/basics/physics_positioning/passive.obj examples/basics/physics_positioning/output
examples/basics/physics_positioning/main.py: path to the python file.
examples/basics/physics_positioning/active.obj: path to the object file with active objects, i. e. objects which we want to participate in physics simulation.
examples/basics/physics_positioning/passive.obj: path to the object file with passive objects, i. e. objects which we do not want to participate in physics simulation, e.g. plane.
examples/basics/physics_positioning/output: path to the output directory.
Visualization
shell
blenderproc vis hdf5 examples/basics/physics_positioning/output/0.hdf5
png
Code
python
# Define a function that samples the pose of a given spheredef sample_pose(obj: bproc.types.MeshObject): obj.set_location(np.random.uniform([-5, -5, 8], [5, 5, 12])) obj.set_rotation_euler(bproc.sampler.uniformSO3())# Sample the poses of all spheres above the ground without any collisions in-betweenbproc.object.sample_poses( spheres, sample_pose_func=sample_pose)
# Make all spheres actively participate in the simulation# 通过循环遍历所有的球体对象 spheres,调用 obj.enable_rigidbody(active=True) 函数使其能够参与物理仿真。其中 active=True 代表该球体是主动物体,需要施加力和碰撞等物理效应。for obj in spheres: obj.enable_rigidbody(active=True)# The ground should only act as an obstacle and is therefore marked passive.# To let the spheres fall into the valleys of the ground, make the collision shape MESH instead of CONVEX_HULL.# 将地面对象 ground 的 enable_rigidbody 函数的 active 设置为 False,表示它是被动物体,只参与碰撞等物理效应,并调整地面的碰撞形状为 MESH,以便让球体可以掉落到地面的洼地中。ground.enable_rigidbody(active=False, collision_shape="MESH")# Run the simulation and fix the poses of the spheres at the end# 调用 bproc.object.simulate_physics_and_fix_final_poses(min_simulation_time=4, max_simulation_time=20, check_object_interval=1) 函数来运行物理仿真并在结束时固定球体的位置。具体而言,min_simulation_time 和 max_simulation_time 分别指示物理仿真的最小和最大时间(秒),check_object_interval 则指示固定物体位置时检查位置的时间间隔(秒)。在本例中,物理仿真时间介于 4s 和 20s 之间,每秒钟检查一次物体位置并固定。(注意:如果没有启用物理,该函数将不起作用。)bproc.object.simulate_physics_and_fix_final_poses(min_simulation_time=4, max_simulation_time=20, check_object_interval=1)
# Use vertex color for texturingfor mat in obj.get_materials(): mat.map_vertex_color()# Set pose of object via local-to-world transformation matrixobj.set_local2world_mat( [[0.331458, -0.9415833, 0.05963787, -0.04474526765165741], [-0.6064861, -0.2610635, -0.7510136, 0.08970402424862098], [0.7227108, 0.2127592, -0.6575879, 0.6823395750305427], [0, 0, 0, 1.0]])# Scale 3D model from mm to mobj.set_scale([0.001, 0.001, 0.001])# Set category id which will be used in the BopWriterobj.set_cp("category_id", 1)